Senior Robotics Engineer · Senior Researcher

I take autonomy from theory to deployed hardware.

Ten years across swarm intelligence, industrial mobile robots and autonomous mobility - a PhD in collective behaviour, production C++ shipped on industrial AMRs, and field robotic deployments from the Venice lagoon to AI deployments in public transport in Austria.

10+
years in robotics
€10M+
EU-funded research
21
peer-reviewed papers
204+
citations

About

I work at the seam where research meets hardware that has to survive contact with the real world.

My PhD asked whether the many bio-inspired swarm behaviours in the literature were really separate algorithms, or one algorithm wearing different clothes. Answering it meant taking theory all the way down to embedded C on robots dropped into the Venice lagoon. Since then I have spent three years writing production C++ for industrial mobile robots, and now lead EU-funded work on autonomous mobility and last-mile delivery at JKU. Some selected work is shown below. Scroll down for the organizations that I have previously worked for.

What connects those is a preference for systems that get built and measured rather than only published. I am most useful on problems that span the whole stack - perception and estimation through planning and control, down to the firmware and the wiring.

Currently based in Linz, Austria, and increasingly focused on bringing learning-based methods into deployed robotic systems.

Capabilities

Autonomy & Navigation
ROS · ROS 2 · NAV2 · SLAM · ICP · NDT · A* · Hybrid A*
Estimation & Control
Particle Filter · Kalman Filter · Sensor fusion · Motion control
Learning & Perception
YOLOvX · CSRNet · Applied ML for mobility
Simulation
NVIDIA Isaac · Gazebo
Languages
C++ · Python · C
Embedded & Hardware
Embedded C/C++ · FreeRTOS · EagleCAD · EtherCAT · CAN · CANopen
Industrial Automation
Mitsubishi PLCs · Sigmatek IO · Kawasaki arms · Yaskawa arms

Selected work

DS Automotion, Linz (2021 - 2024)

Fastbots

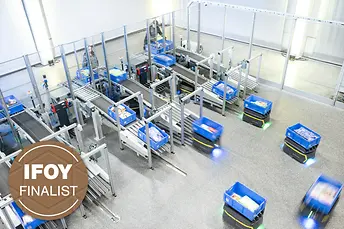
Core localization and control software for a prominent industrial mobile robot

Built the core localization interface and C++ control modules for Fastbots, a prominent, agile industrial mobile robot platform. Drove hardware integration, software development and testing across its first three iterations, taking it from prototype to product.
  • C++
  • ROS
  • Localization
  • Particle Filter
  • CAN / CANopen
  • EtherCAT
  • Embedded

Johannes Kepler University, Linz (2024 - Present)

OptiPEX & Autonomous Mobility

Leading EU-funded work on last-mile delivery and pedestrian safety around autonomous vehicles

Technical lead for the EU-funded OptiPEX project optimizing passenger experience in public transport systems. My work here leads the development of onboard occupancy detection and a novel pedestrian localization system, based on ultra-wideband technology, that reduces collision risk with pedestrians in shared spaces.

  • ROS 2
  • Ultra Wide Band
  • Machine Learning
  • V2P / V2X
  • Pedestrian Safety
  • Field Experiments

Johannes Kepler University, Linz (2026)

F1TENTH Autonomous Racing

Lidar-only autonomy on a 1/10-scale race car - from a Nav2 baseline to a custom MPC

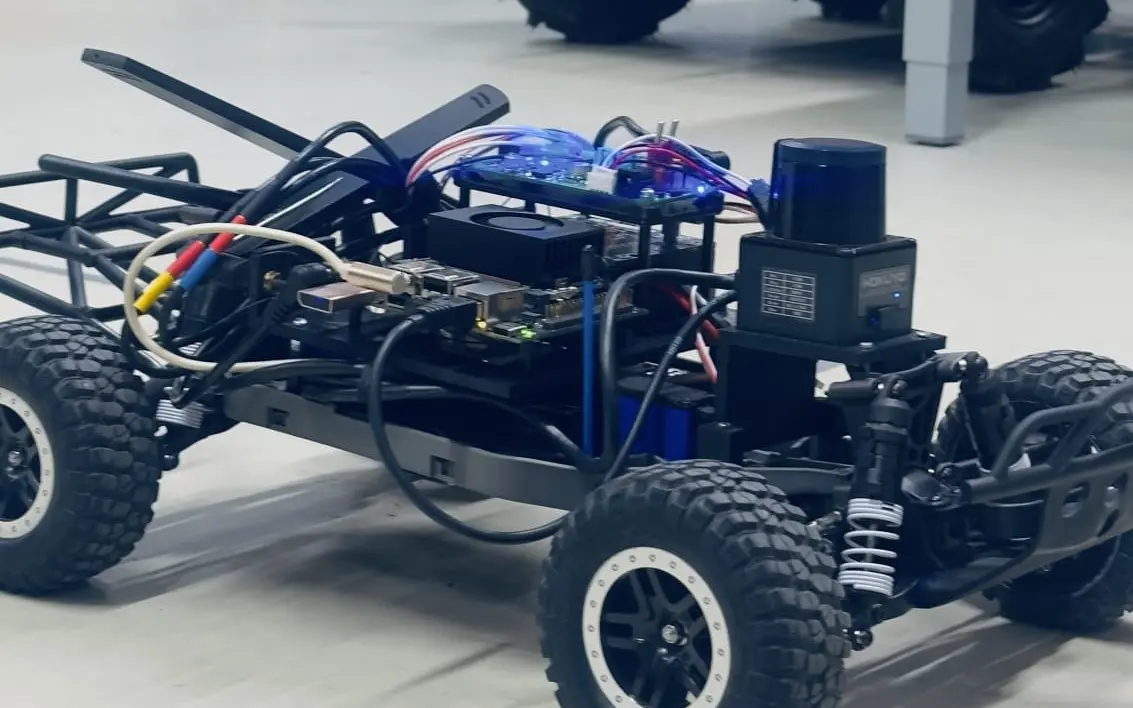
Led the design and build of JKU's F1TENTH autonomous racing platform end to end - hardware and software. A lidar-only ROS 2 stack running on a Jetson AGX Xavier, closing a 50 Hz control loop with a purpose-built MPC that replaced an initial Nav2 baseline and went from integration to race-ready in two weeks. Placed 10th at ICRA 2026 in Vienna, the team's first competition.

  • ROS 2
  • MPC
  • Nav2
  • Jetson AGX Xavier
  • 2D Lidar
  • C++
  • Real-time control
  • Autonomous racing

Artificial Life Lab, University of Graz (2015 - 2021)

Underwater Robot Swarms

One design paradigm for collective behaviour - formalised in a PhD, validated in the Venice lagoon

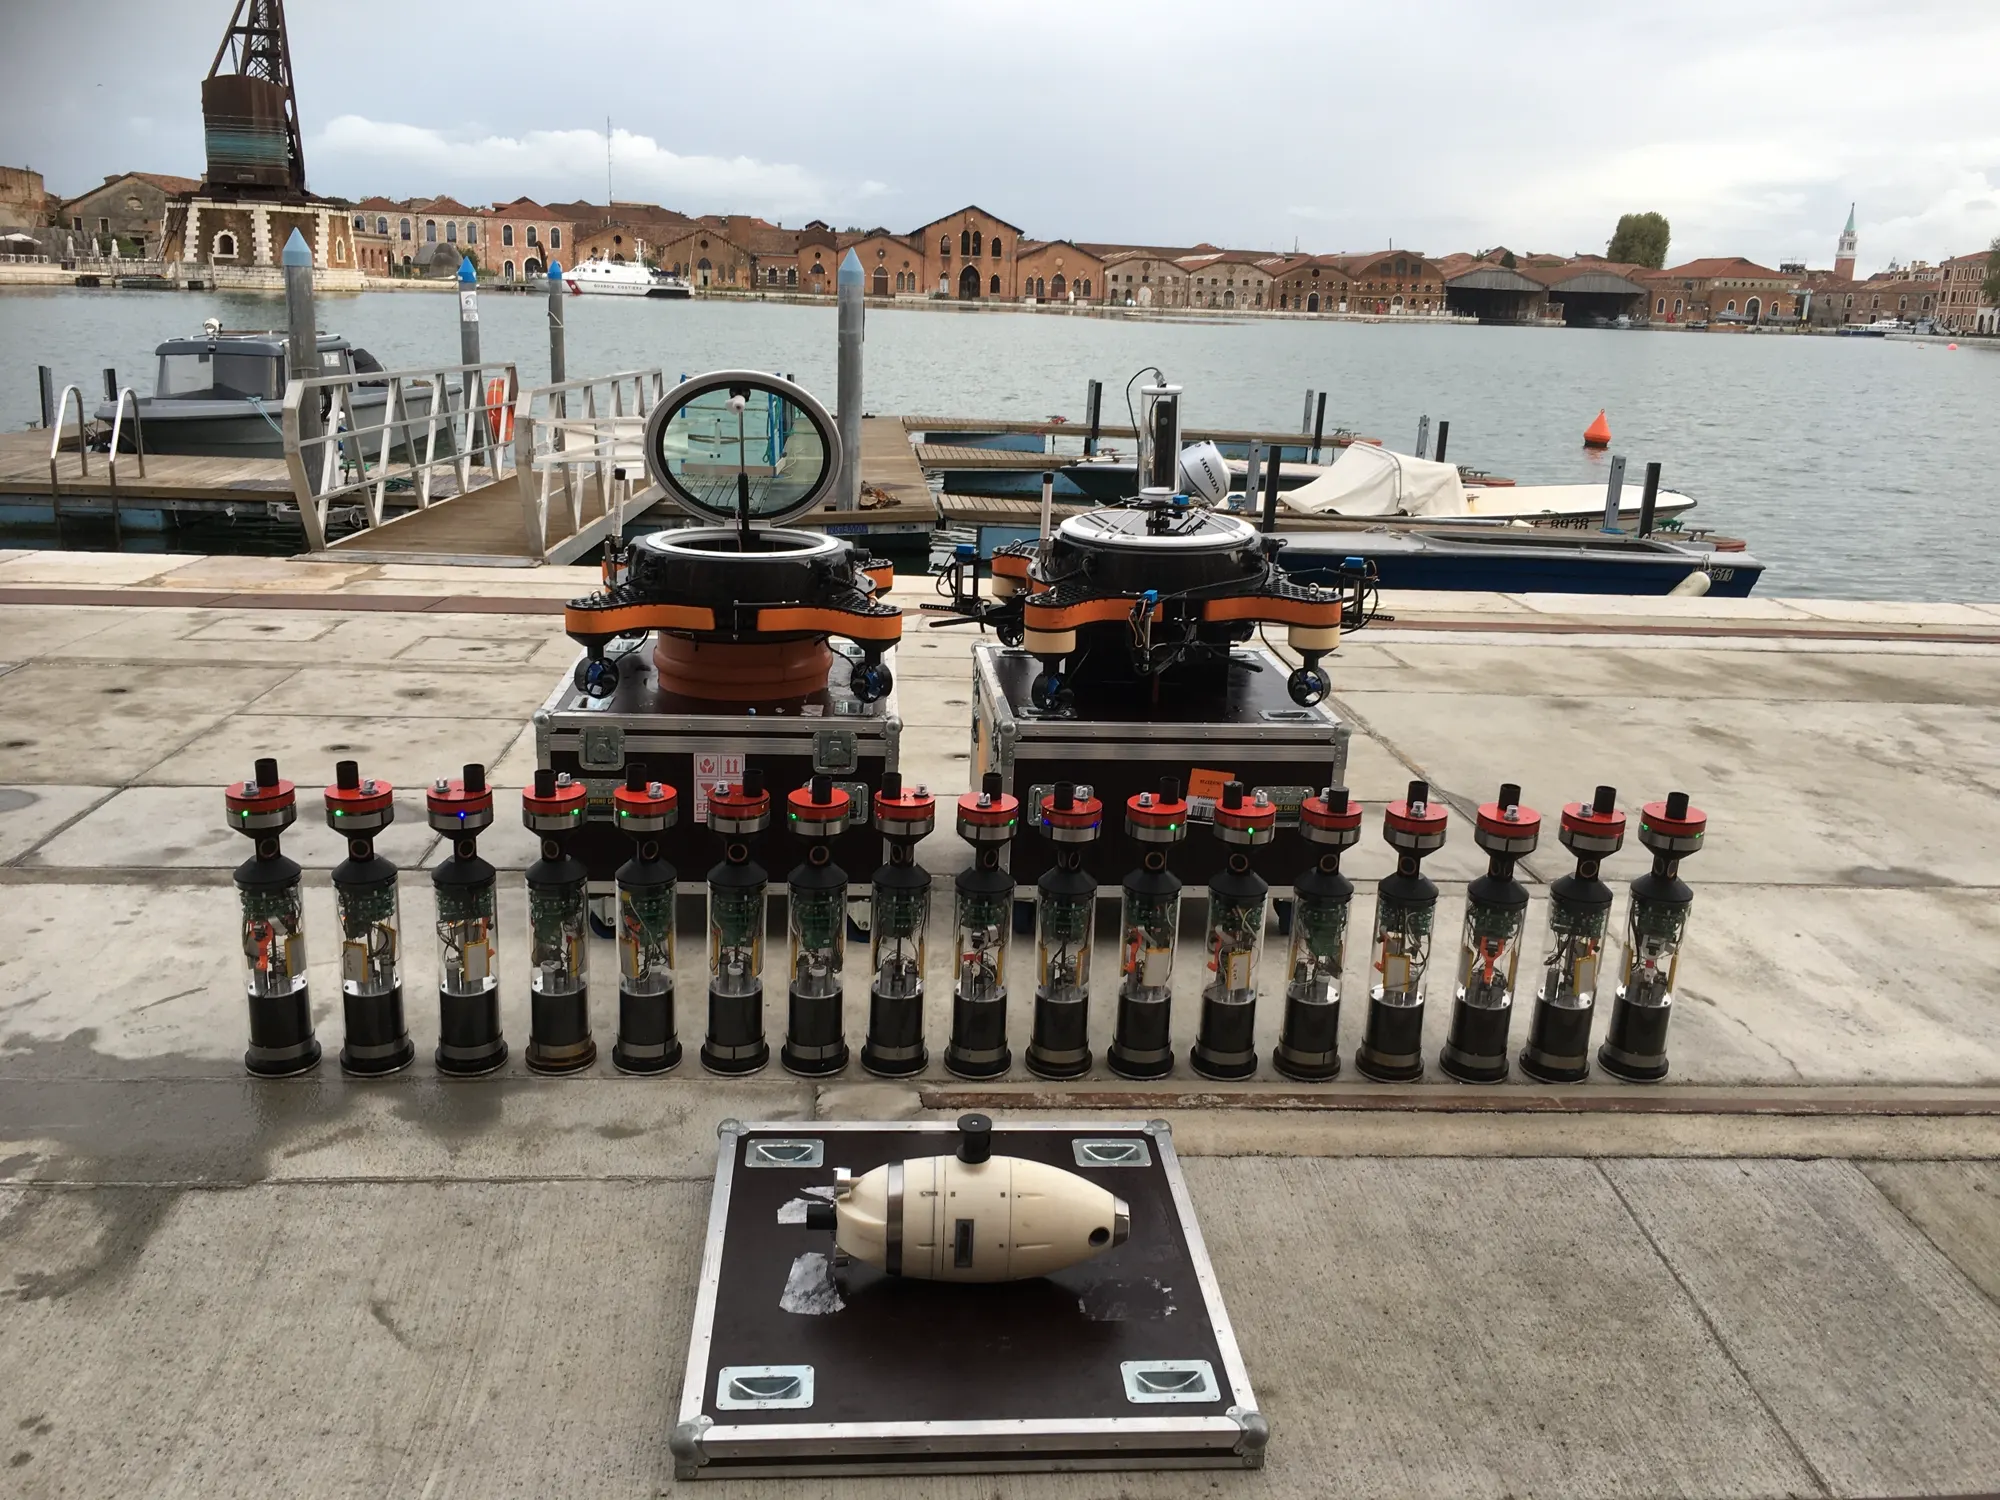
Six years on subCULTron, designing and deploying swarms of underwater robots that coordinate through minimalistic local communication - no central controller, no global state. The doctoral strand argued that the sprawling family of bio-inspired swarm algorithms consists largely of instances of a single design paradigm; the field strand took that paradigm down to embedded C/C++ and into the Venice lagoon.

  • Swarm Intelligence
  • Distributed Algorithms
  • Collective Behaviour
  • Embedded C/C++
  • Field Robotics
  • Sensor Fusion
  • Simulation

Experience

  1. 04/2024 - Present

    Johannes Kepler University Linz, Austria

    Postdoctoral Researcher, Intelligent Transport Systems

    • Leading development of last-mile delivery and autonomous mobility capabilities within the department.
    • Technical lead and coordinator for the EU-funded OptiPEX project, aligning research, industry stakeholders and public transport innovation initiatives.
    • Lecturer for “Introduction to Autonomous Vehicles”, mentoring graduate students in autonomy stacks and system integration.
    • Applied research in machine learning for mobility and intelligent transportation systems.
  2. 09/2021 - 03/2024

    DS Automotion GmbH Linz, Austria

    Robotics Core Software Developer

    • Built C++ drivers and control modules for industrial mobile robots - localization, actuation and battery systems.
    • Spearheaded hardware integration, software development and testing of the Fastbots system across its first three iterations.
    • Implemented the core localization interface and other central components of the shipped Fastbots product.
    • Contributed to software architecture decisions for scalable, production-grade autonomous systems.
    • Worked across mechanical, electrical and product teams to move prototypes onto deployable robotic platforms.
  3. 11/2015 - 07/2021

    Artificial Life Lab, University of Graz Graz, Austria

    Researcher

    • Designed and implemented bio-inspired swarm intelligence algorithms for multi-robot systems in simulation and on physical robots.
    • Developed embedded C/C++ software for sensing, communication and actuation modules.
    • Ran real-world underwater robotic field deployments in the Venice lagoon, validating distributed control strategies outside the lab.
    • Designed and implemented embedded temperature gradient systems for classrooms.
    • Published extensively in swarm robotics, adaptive systems and collective intelligence.
  4. 06/2012 - 10/2015

    Micron Semiconductor Asia Ltd. Singapore

    Process Engineer

    • Process owner for four FEOL photolithography processes during a 3D NAND ramp-up.
    • Led troubleshooting and qualification of tools using statistical process control.
    • Served as shift-in-charge during the critical production startup phase.
  5. 06/2010 - 07/2012

    Maruti Suzuki India Ltd. Gurgaon, India

    Assistant Manager, Plant Maintenance

    • Reduced robotic system downtime from 7 days to 1 day by introducing offline testing and training systems.
    • Developed a statistical analysis tool to identify chronic breakdown patterns and improve preventive maintenance planning.
    • Led maintenance teams responsible for industrial robotic arms and plant automation systems.

Education

  1. 11/2015 - 11/2019

    Graz University of Technology (TU Graz)

    PhD in Computer Science

    Investigated a unifying paradigm to unite bio-inspired collective behaviours and validated it on real robots. Advisors: Prof. Franz Wotawa, Prof. Thomas Schmickl.

  2. 07/2012 - 06/2013

    National University of Singapore (NUS)

    MSc in Mechatronics

    Major in control systems and embedded systems. GPA 4.25/5.

  3. 08/2006 - 05/2010

    National Institute of Technology (NIT), Jamshedpur

    BTech, Electrical and Electronics Engineering

    Major in control systems and embedded systems. GPA 8.92/10.

Contact

Open to roles bringing learning into deployed robotic systems.

If you are working on robot learning, autonomous mobility, or moving research-grade autonomy into products, I would like to hear about it.